Featured Projects
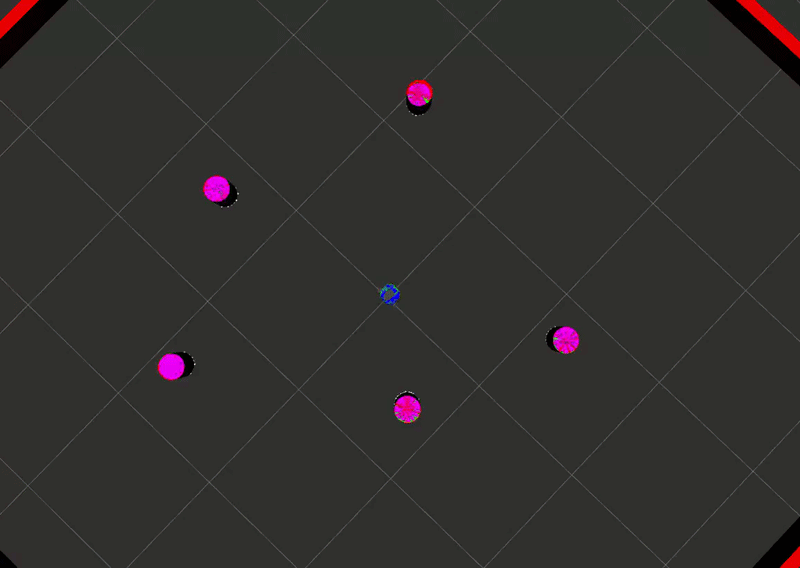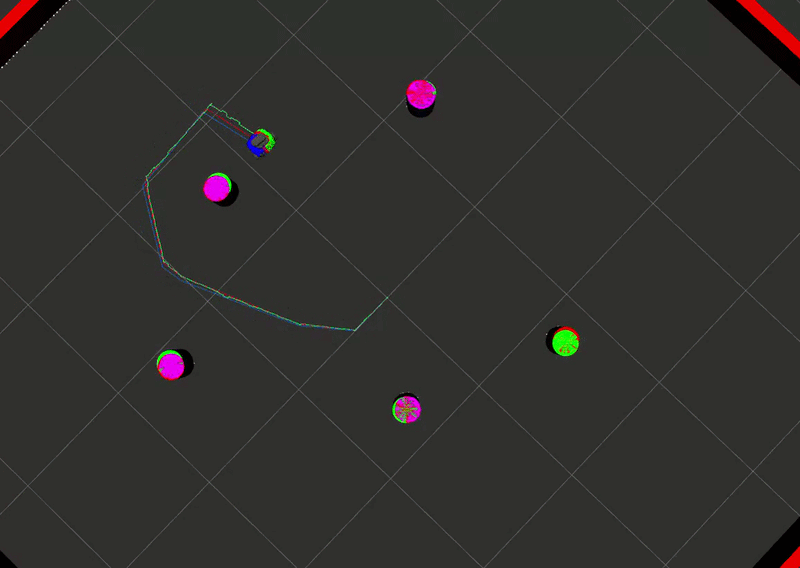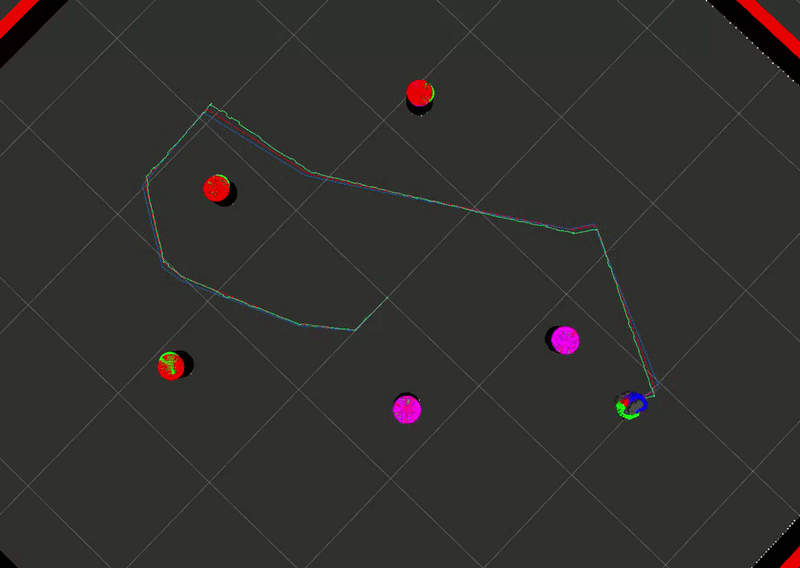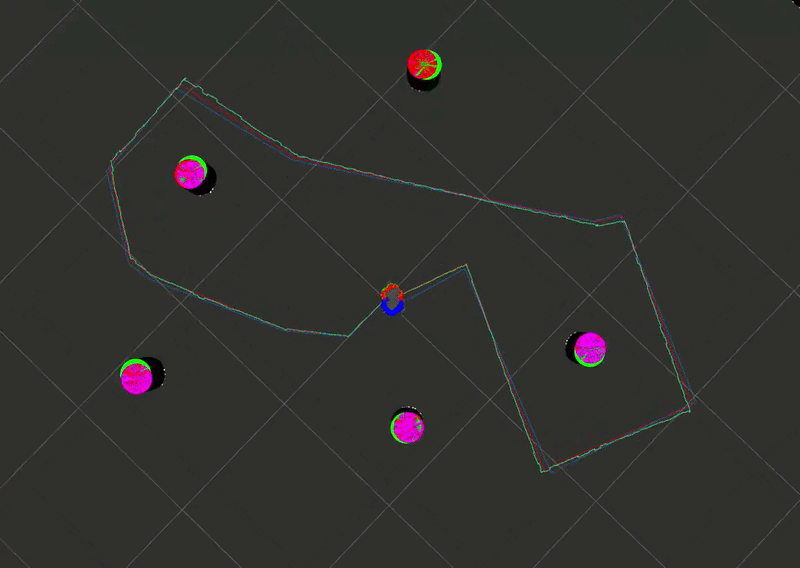
Turtlebot3 EKF SLAM from Scratch
A full Simultaneous Localization and Mapping (SLAM) stack for ROS 2 in C++ from scratch for Turtlebot3 Burger.
GitHub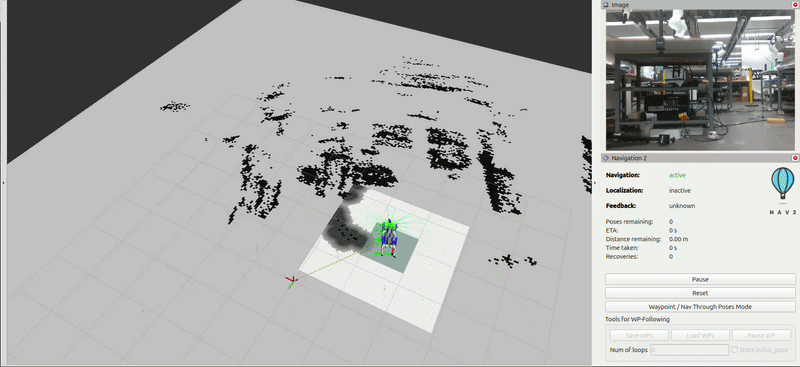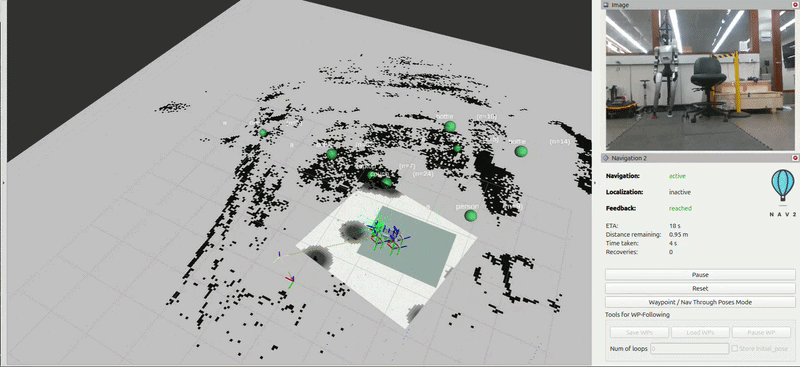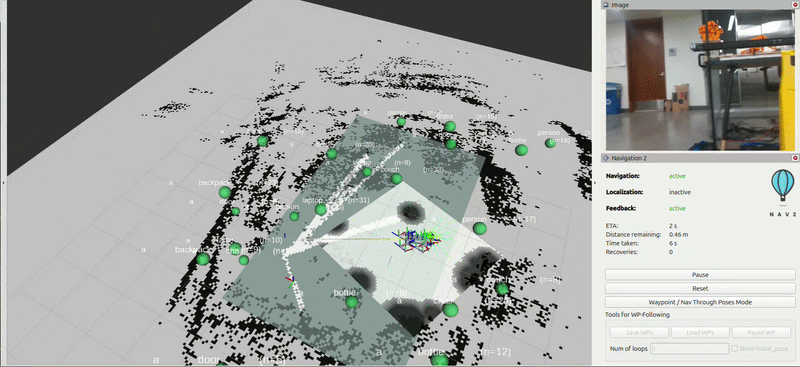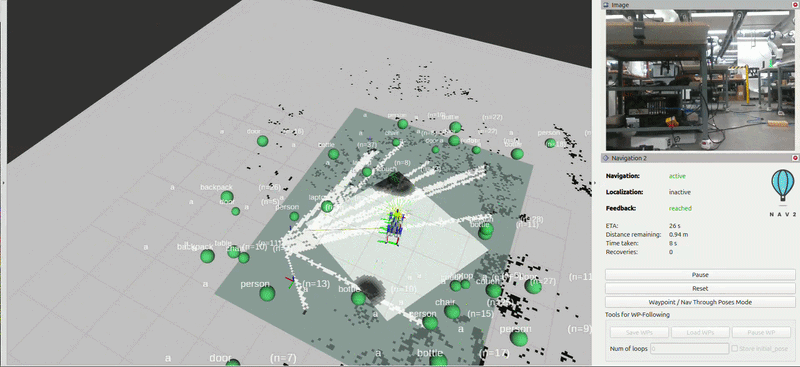
Open Vocabulary Semantic Memory for Unitree Go2
An autonomous navigating Unitree Go2 which builds an open vocabulary memory of its surroundings with SAM3 and CLIP
GitHub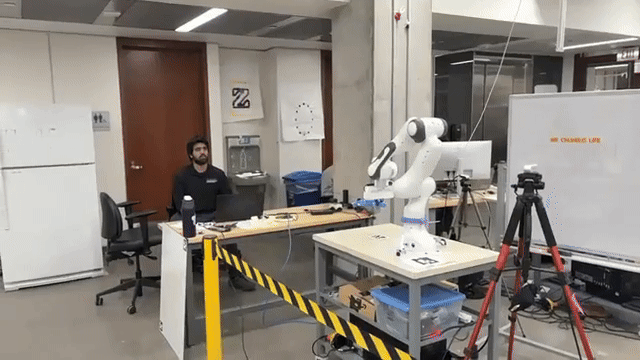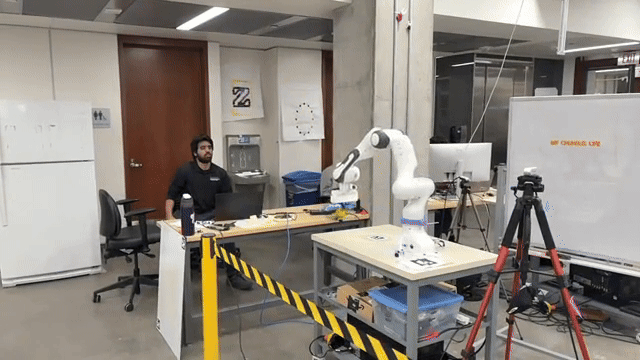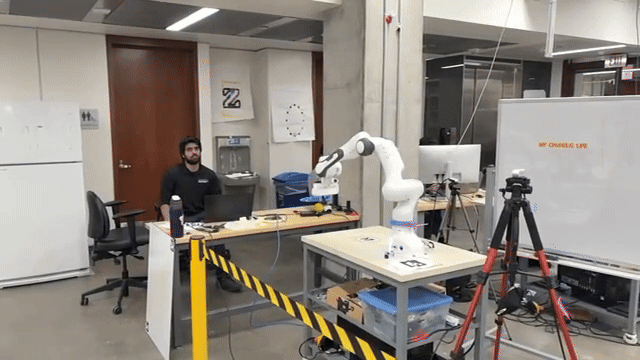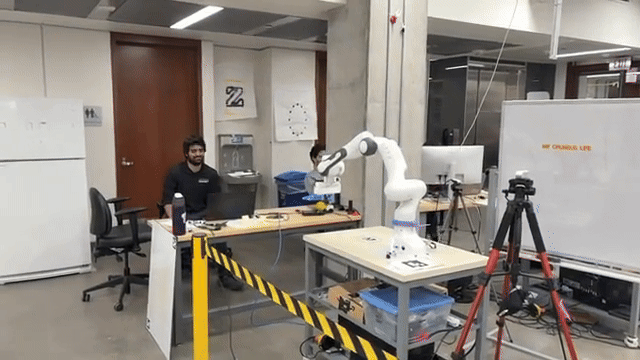
Ball Catching Franka Arm with YOLO
Real-time ball detection using YOLO and stereo vision combined with least squares analysis trajectory prediction and the MoveIt2 libray for franka arm control.
GitHubMore Projects
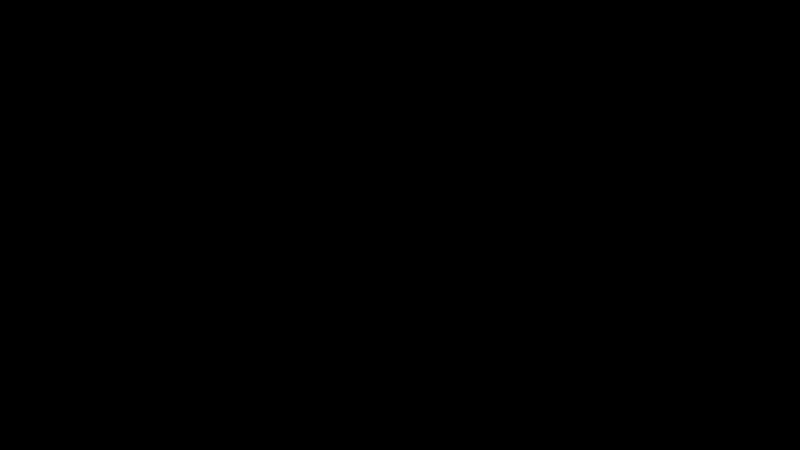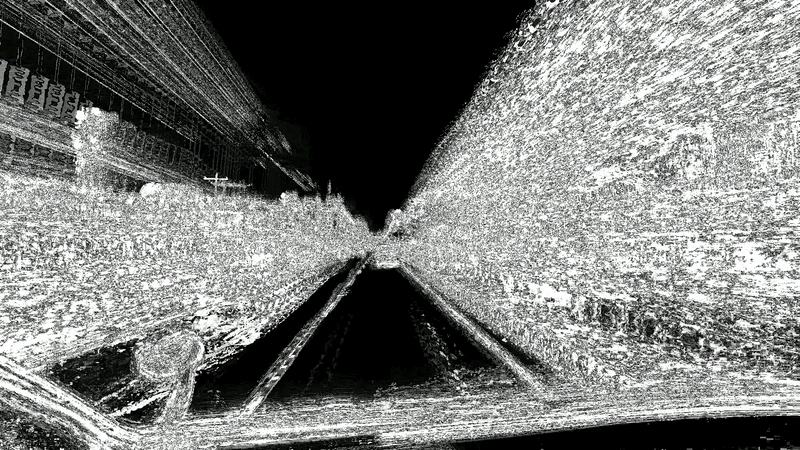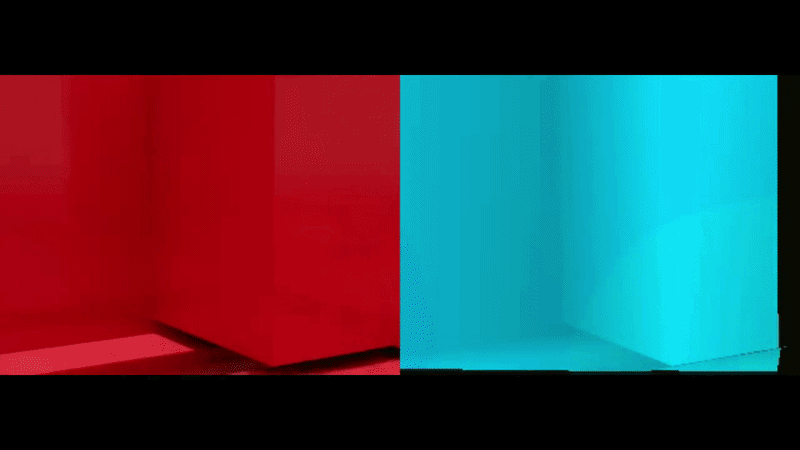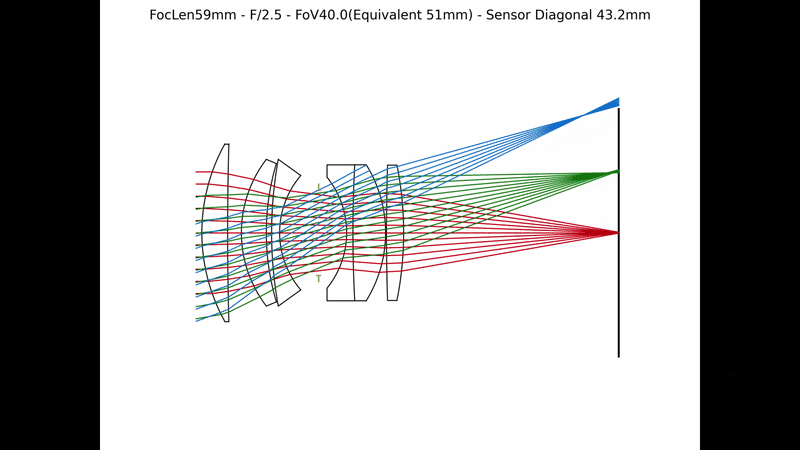
Towards a Unified Differentiable Pipeline
An exploration of the methods required to design a differentiable end-to-end event camera learning pipeline with Pytorch
GitHub
Jack in a Cup Impact Simulation
Simulation of Impact Conditions when Jack is being thrown around a shaking cup, utilizing Euler Lagrage Equations, the Impact Equations, and python.
GitHub
OpenCV Pen Stealing Robot Arm
Watch out! Utilizing OpenCV, this robot can see purple pens, identify their location, and will reach out to steal them. Keep your pens close!
GitHub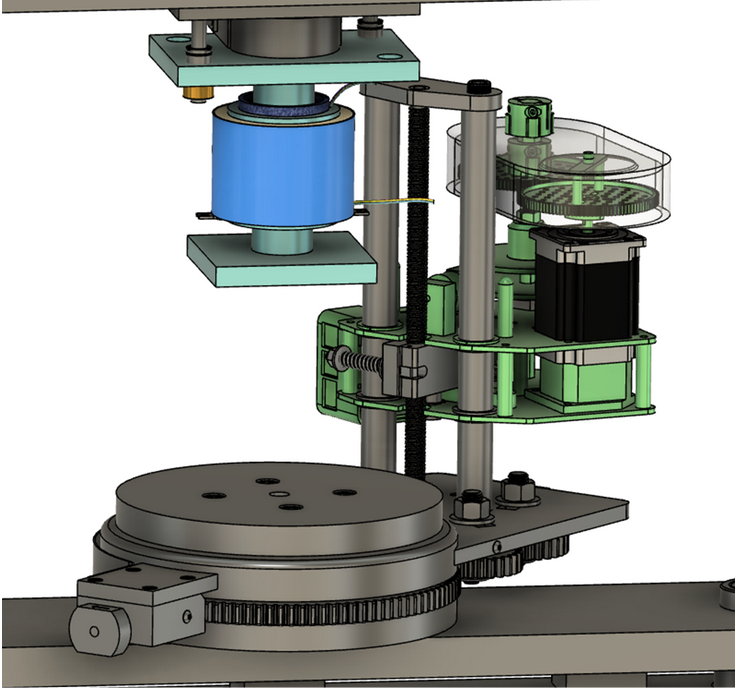
Wrapping Tension Control
Designed, programed, and implemented a device which can measure and control tension of fiberglass tape during Sandia Laboratories’ thermal battery wrapping procedure.
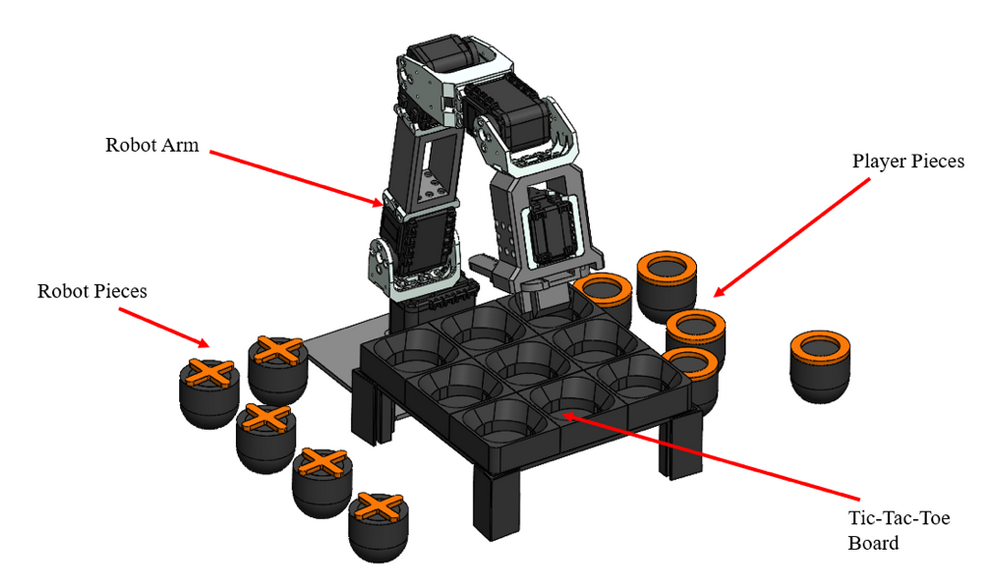
Tic Tac Toe playing robot arm
Robot arm which never loses tic tac toe, utilzing inverse kinematics and predetermined positions for game play and the minimax algorithm for decision making
Experience
Robotics Software Engineering Intern
Vermeer · Brooklyn, NY- Optimized FR-20 cobot camera calibration for a high-precision computer vision pipeline.
- Worked on advanced state-estimation algorithms, developed tools for covariance scaling analysis.
Began Masters of Science in Robotics
Northwestern University · Evanston, IL- Began transition from primarily mechanical design engineer to full-stack robotics engineer.
- Gained pivotal exposure across projects to ROS 2, perception algorithms, and machine learning.
Engineering Intern
Willow · Mountain View, CA- Prototyped multi-antenna Bluetooth Channel Sounding distance-measurement firmware in C.
- Performed DFU and system validation of embedded firmware on 150 Willow Sync pumps.
Graduated with Mechanical Engineering Degree
University of Illinois Urbana-Champaign · Champaign, IL- Completed thermal battery wrapping station senior design project for Sandia National Labs, including an in person visit.
- Completed a CS Minor, began growing exposure to automated system design.
Mechanical Engineering Intern
Willow · Mountain View, CA- Used NX and SLA printing to rapidly fabricate soft-plastic prototypes.
- Created test models and generated vacuum waveforms.
R&D Intern
Ancora Heart · Santa Clara, CA- Executed verification testing, fixture development, and data analysis for catheter performance evaluation.
- Assembled and programmed (in C) an automated catheter-braiding system, cutting braiding time by 50%.